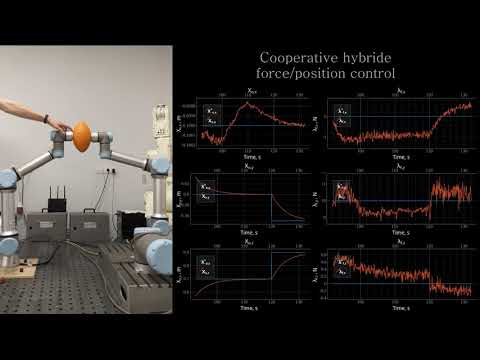
Cooperative hybride force/position control algorithm for holding an object 1:23 | A processar vídeo... A Carregar... Transferir